Yiyang Ling 凌逸飏I am a third year PhD student in Computer Science at University of Southern California, advised by Prof. Daniel Seita. I received my Bachelor's degree at ACM Honors Class, Shanghai Jiao Tong University. Previously, I was a visiting student at University of California San Diego, under the supervision of Prof. Xiaolong Wang. Before this, I gained valuable experience as a research assistant in the SJTU Machine Vision and Intelligence Group, where I was advised by Prof. Cewu Lu. My research focuses on contact-rich robotic manipulation and multi-modal robot learning, particularly leveraging vision and tactile sensing to enable robust physical interaction. Feel free to contact me if you are interested in my work or would like to collaborate! Email / GitHub / Google Scholar / Twitter / LinkedIn |

|
Research |

|
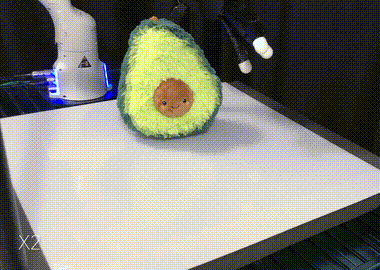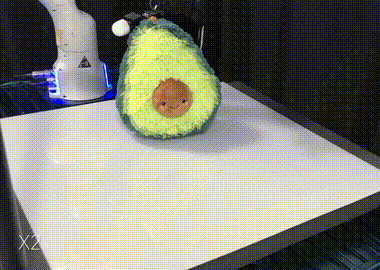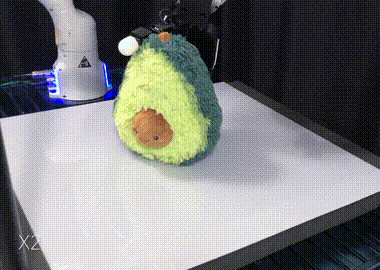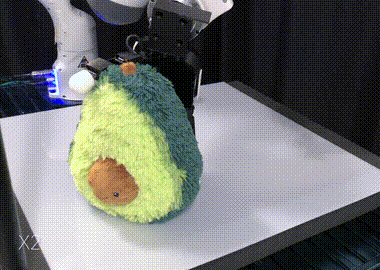
FELT: Generating Tactile Signals from Vision for Visuo-Tactile ManipulationZinan Li*, Yiyang Ling*, Yuming Gu, Binghao Huang, Chenhao Liang, Sharfin Islam, Hisham Bedri, John Chirikjian, Yunzhu Li, Stefanos Nikolaidis, Daniel Seita Workshop on Tactile Sensing for Robotic Foundation Models, RSS 2026 arxiv / website We present a vision-to-touch framework that generates per-finger tactile signals directly from RGB observations. By augmenting vision-only demonstrations with generated tactile images or latent features, FELT enables visuo-tactile policy learning without requiring physical tactile sensors. Across multiple contact-rich real-world manipulation tasks, it consistently improves performance over vision-only policies. |
|
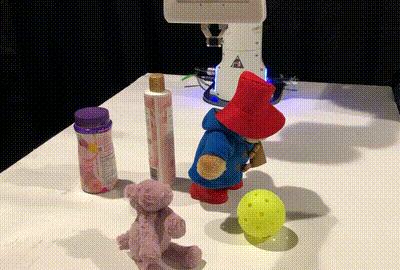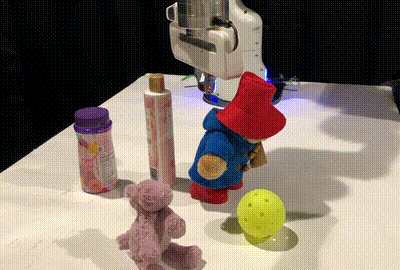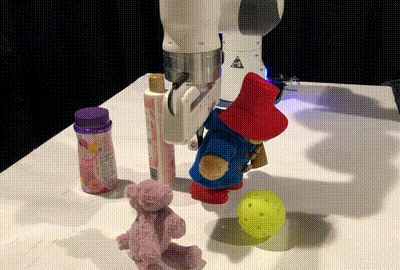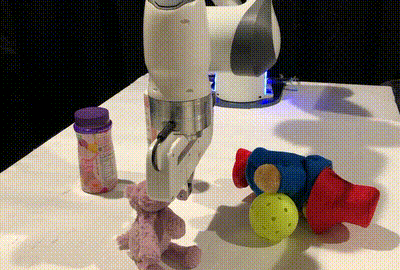
Learning Geometry-Aware Nonprehensile Pushing and Pulling with Dexterous HandsYunshuang Li, Yiyang Ling, Gaurav Sukhatme†, Daniel Seita† International Conference on Robotics and Automation (ICRA), 2026 arxiv / website / code We propose Geometry-aware Dexterous Pushing and Pulling, a method for nonprehensile manipulation which frames the problem as synthesizing and learning pre-contact dexterous hand poses that lead to effective pushing and pulling. |
|
IMPACT: Intelligent Motion Planning with Acceptable Contact Trajectories via Vision-Language ModelsYiyang Ling*, Karan Owalekar*, Oluwatobiloba Adesanya, Erdem Bıyık, Daniel Seita International Conference on Robotics and Automation (ICRA), 2026 arxiv / website / code We introduce IMPACT, a novel motion planning framework that uses Vision-Language Models to infer environment semantics, identifying which parts of the environment can best tolerate contact based on object properties and locations. Results both in simulation and real-world suggest that IMPACT enables robots to efficiently reach targets while making semantically acceptable contact when needed. |
|
GenSim: Generating Robotic Simulation Tasks via Large Language ModelsLirui Wang, Yiyang Ling*, Zhecheng Yuan*, Mohit Shridhar, Chen Bao, Yuzhe Qin, Bailin Wang, Huazhe Xu, Xiaolong Wang Workshop on Language Grounding and Robot Learning, CoRL 2023 (Best Paper); International Conference on Learning Representations (ICLR), 2024 (Spotlight) arxiv / website / code In this work, we propose to automatically generate rich simulation environments and expert demonstrations by exploiting LLMs’ grounding and coding ability. Our approach has two modes: goal-directed generation, wherein LLM proposes a task curriculum to solve a target task, and exploratory generation, wherein LLM bootstraps from previous tasks and iteratively proposes novel complex tasks. |
Education |
|
University of Southern CaliforniaAug 2024 - Present Ph.D. student in Computer Science |
|
Shanghai Jiao Tong UniversitySep 2020 - Jun 2024 B.S. in Computer Science |
|
Design and source code from Leonid Keselman's website |